Device documentation
I/O mapping for Altera DE1-SoC
By: WebLab-Deusto (University of Deusto) , Giovanna Lani (WebLab-Deusto, University of Deusto)
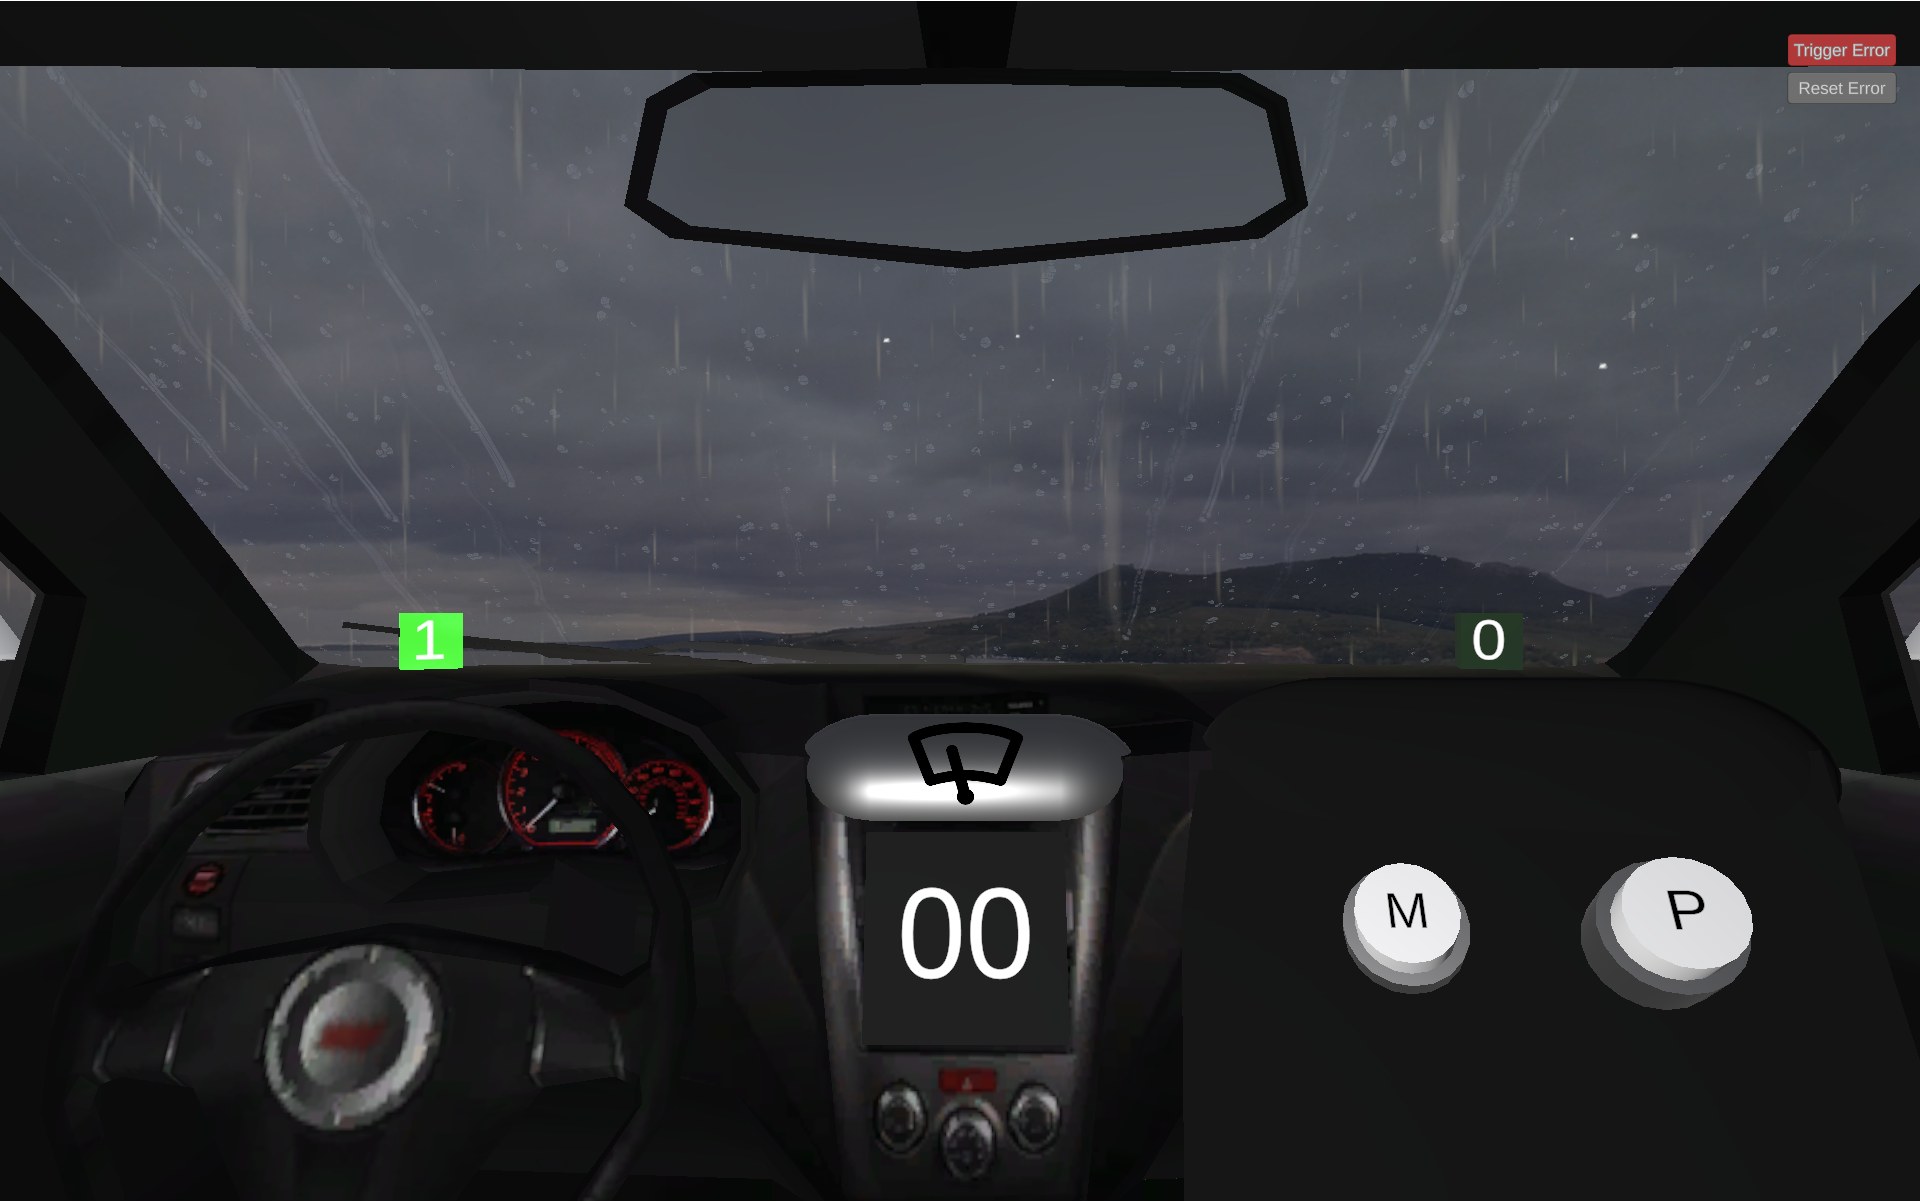
Wiper (two-bit) DE1-SoC I/O mappings
All signals are active high. GPIO numbers refer to the LabsLand virtual GPIO
bus; in VHDL, for example, GPIO 28 is V_GPIO(28).
| Runtime signal | Meaning in the current simulation | Type | GPIO |
|---|---|---|---|
rainSensor |
Rain is active | FPGA input | GPIO 28 (V_GPIO(28)) |
rightSensor |
Wiper is at the left-hand limit | FPGA input | GPIO 29 (V_GPIO(29)) |
leftSensor |
Wiper is at the right-hand limit | FPGA input | GPIO 30 (V_GPIO(30)) |
mButton |
The interface's M button is being pressed | FPGA input | GPIO 23 (V_GPIO(23)) |
pButton |
The interface's P button is being pressed | FPGA input | GPIO 24 (V_GPIO(24)) |
move1 |
First movement-control signal | FPGA output | GPIO 26 (V_GPIO(26)) |
move2 |
Second movement-control signal | FPGA output | GPIO 27 (V_GPIO(27)) |
The command pair is written in (move1, move2) order:
move1 / GPIO 26 |
move2 / GPIO 27 |
Result |
|---|---|---|
| 0 | 0 | Stop |
| 0 | 1 | Move toward the right-hand limit |
| 1 | 0 | Move toward the left-hand limit |
| 1 | 1 | Error state |
The current two-bit simulation publishes the endpoint channels with their
runtime names reversed: rightSensor reports the physical left-hand limit and
leftSensor reports the physical right-hand limit. This is different from the
one-bit Wiper. Use the endpoint meanings in the table above when implementing a
controller. Between the endpoints, both endpoint sensors can be low.